Senior Mechatronics Engineer working full time at Rockslice, and an industrial PhD candidate at NTNU. 6+ years in surgical and construction robotics. Based in Bergen, Norway.
I take robotic systems from concept to field test: mechanical design, controls, firmware, and manufacturing
ABOUT
I’m Liam, a mechatronics engineer with 6+ years in surgical and construction robotics, based in Bergen, Norway. I work full time as a Senior Mechatronics Engineer at Rockslice, where I was the first engineering hire and build explosive-free robotic rock and concrete cutting. Alongside that I am pursuing an industrial PhD through NTNU’s Field Robotics Lab, in partnership with Rockslice, on advanced control and material sensing for the cutting platform. Before that I was a mechanical engineer at Ethicon (formerly Auris), working on Johnson & Johnson’s Ottava surgical robot, and I hold an M.Sc. in Mechatronics from MCI Innsbruck and a B.Sc. in Aerospace Engineering from Cal Poly San Luis Obispo.
LIAM NOLAN — BERGEN, NORWAY
RESUME
Mechatronics engineer with 6+ years in surgical and construction robotics, working full time at Rockslice while pursuing an industrial PhD at NTNU.
Sept 2025 – present
Bergen, NO
Full timeSenior Mechatronics Engineer
Rockslice
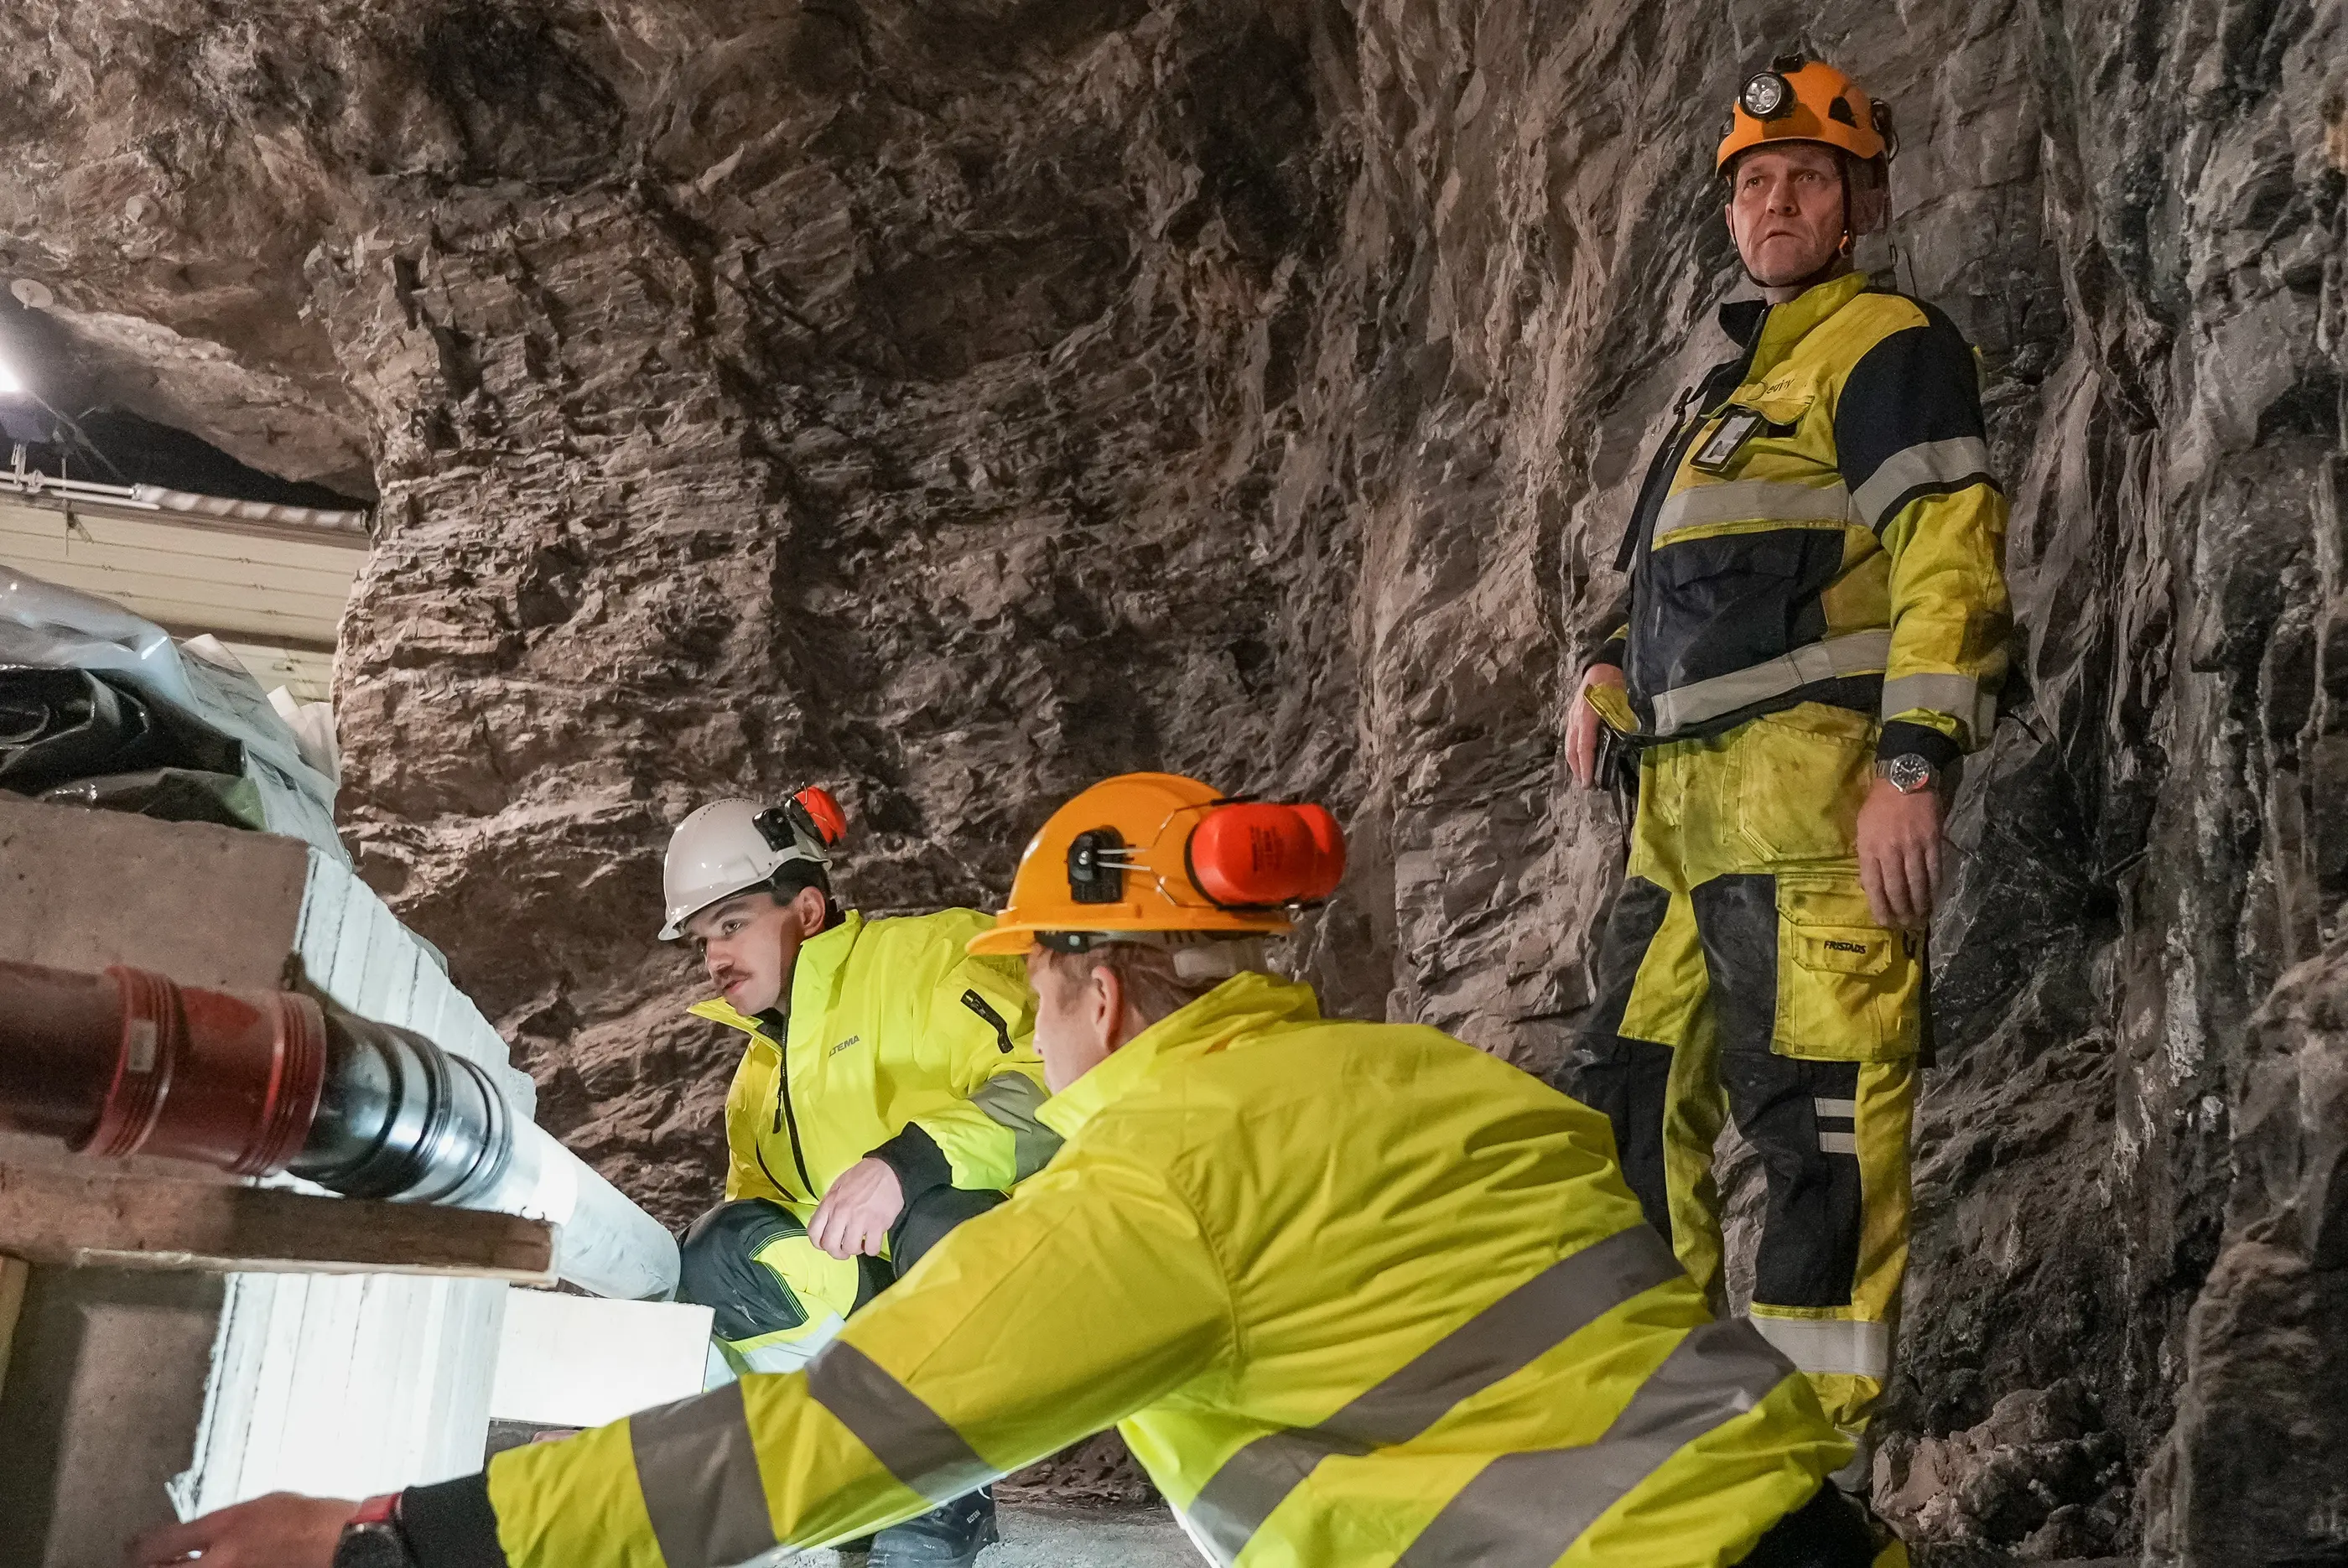
National Startup Award 2024 winner: explosive-free robotic rock and concrete cutting.
- First engineering hire, owning design, prototyping and testing
- Redesigned the patented water-turbine sword saw: 10× cheaper, 20 → 10 kg, cut depth 1 → 1.5 m
- Designed a 3-DoF robotic sword positioner for flush, square-cornered cuts in confined spaces
- Leading the company’s first customer pilot project (December 2026)
Autumn 2026 – present
Department of Mechanical and Industrial Engineering
Alongside RocksliceIndustrial PhD Candidate
NTNU, Field Robotics Lab
Research Council of Norway industrial PhD, in partnership with Rockslice.
- Proposed thesis: Optimizing Material Removal Rates in Robotic Stone and Concrete Cutting through Advanced Control and Material Sensing
2024 – 2025
Innsbruck, AT
Master’s Thesis
MCI
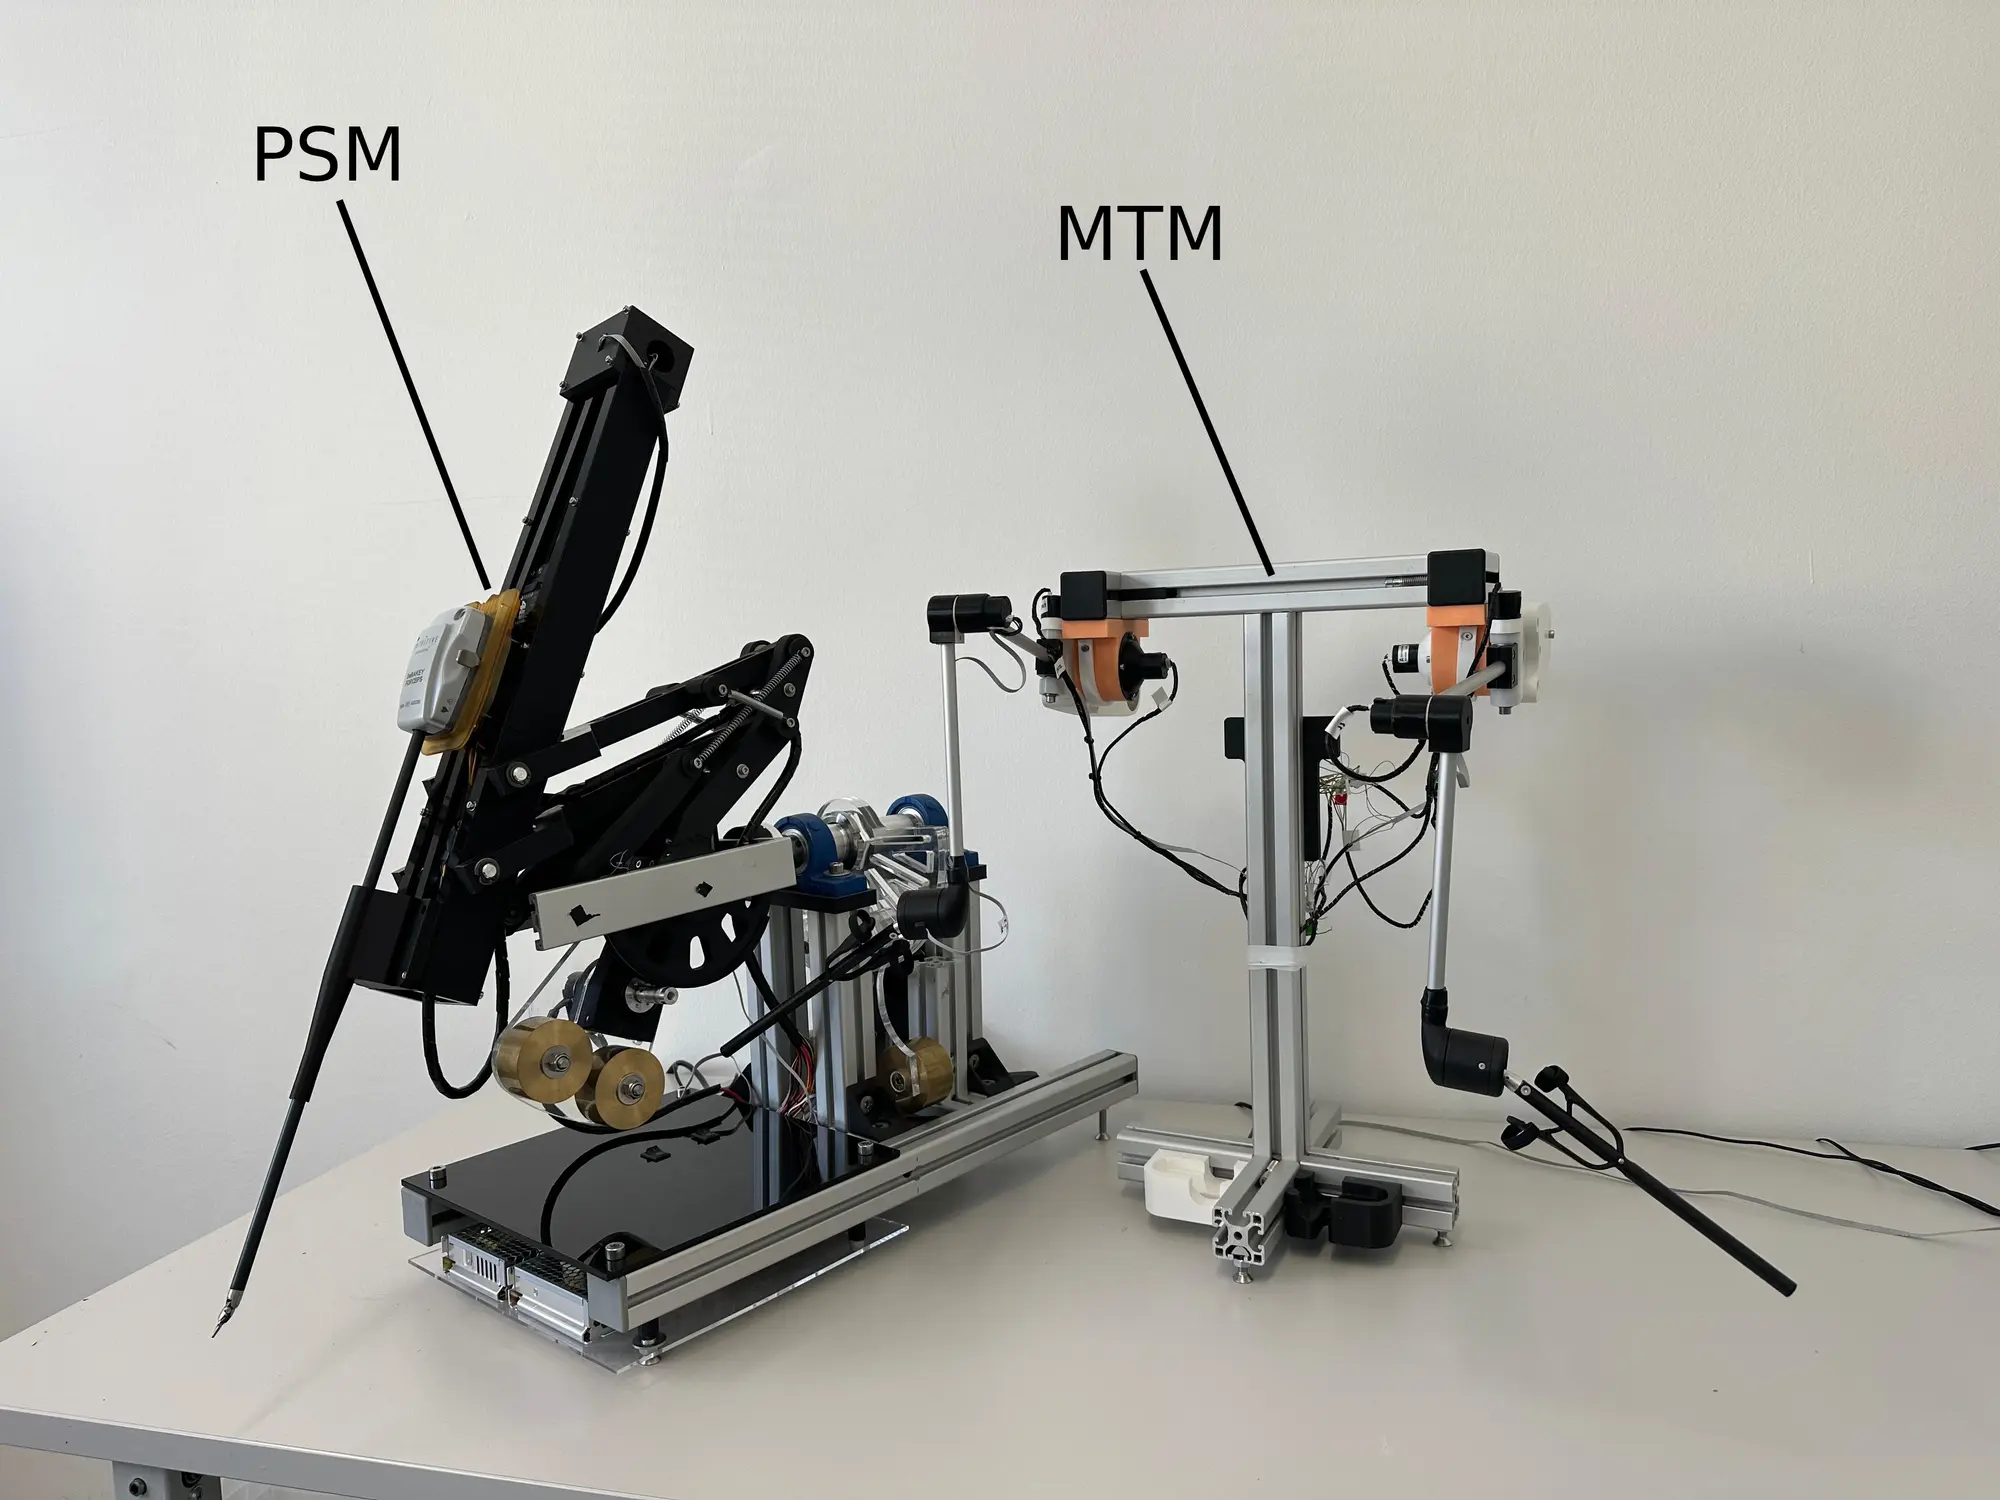
ROS 2-based Implementation of Advanced Control for a Teleoperated Surgical Robot.
- Ported a surgical teleoperation robot to ROS 2 / micro-ROS in C++
- Gain-scheduled LQR and LQI + feedforward control from closed-loop PRBS system identification
- Reduced mean tracking error by 94% (pitch) and 74% (roll) vs. proportional control
- First-author paper at IEEE ICARM 2026
2019 – 2023
Santa Clara, CA
Mechanical Engineer
Ethicon Inc. (formerly Auris)
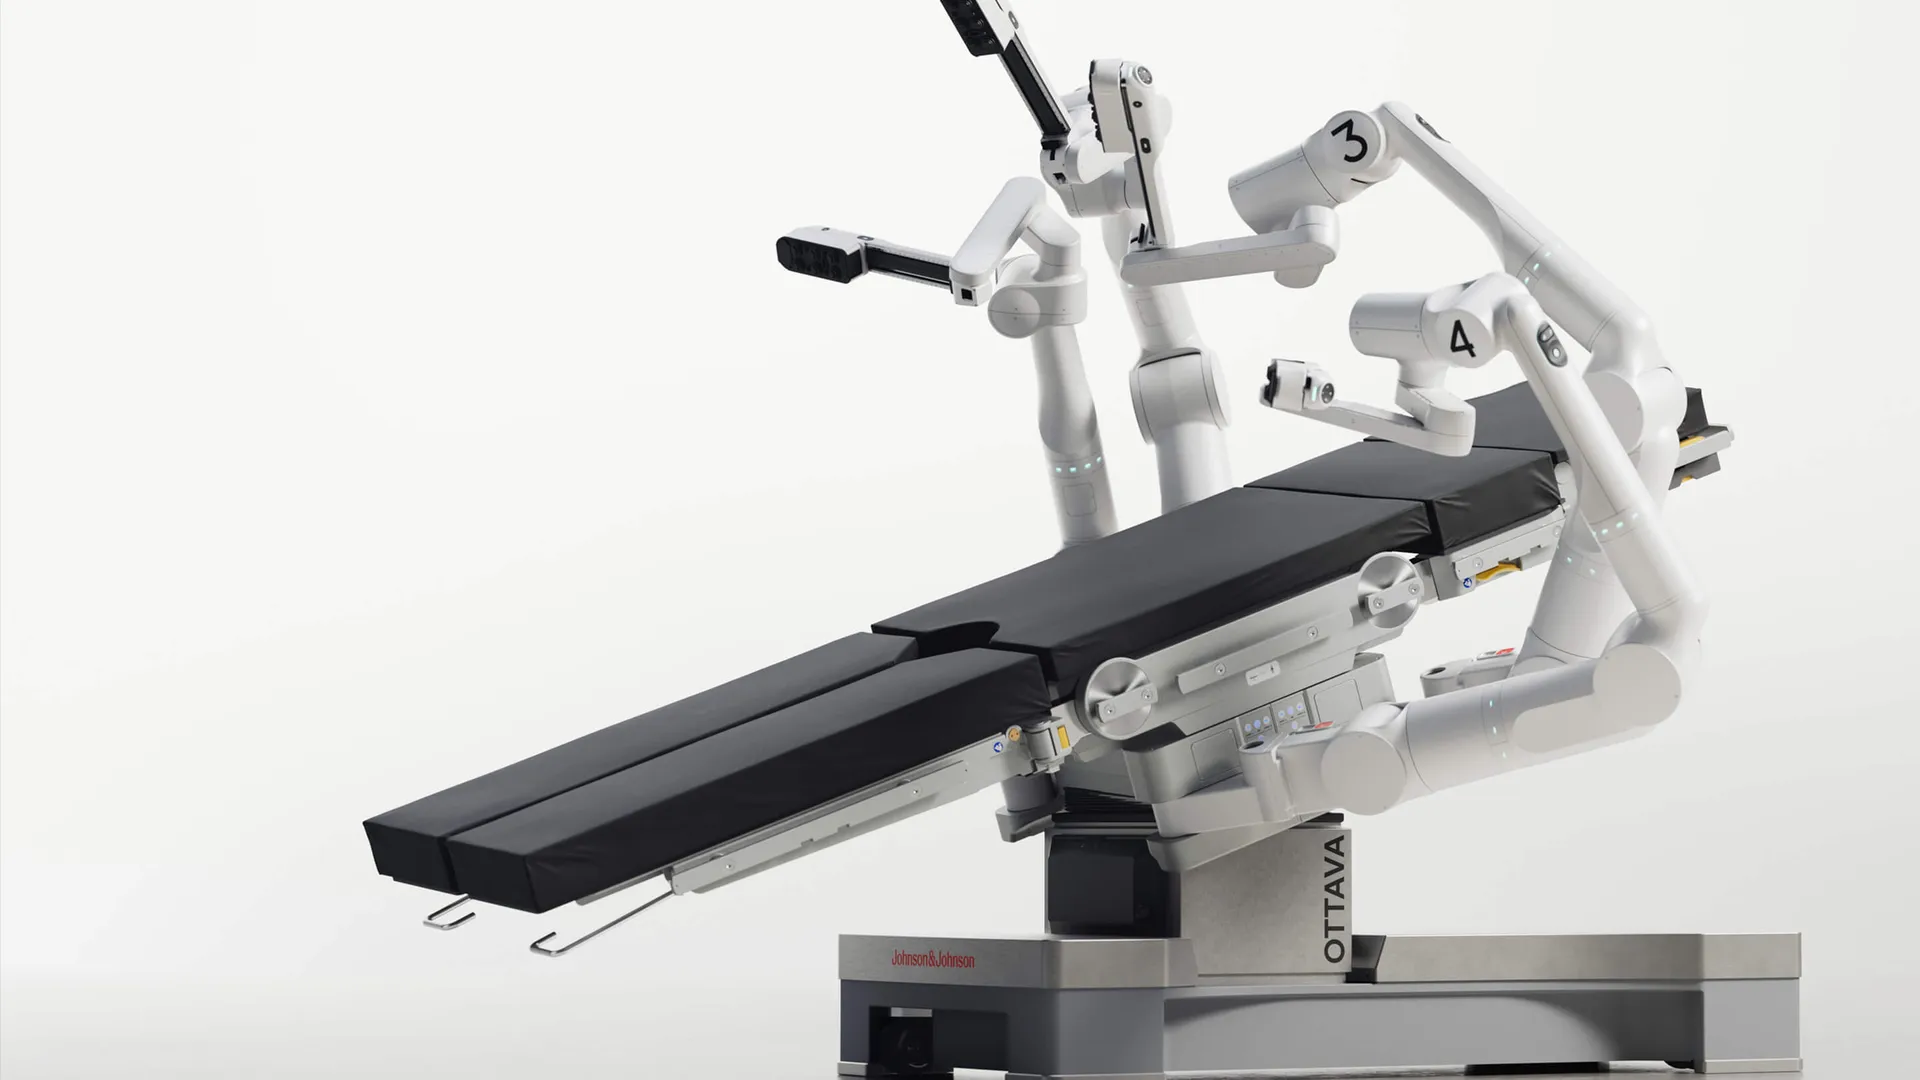
Johnson & Johnson surgical robotics: the Ottava soft-tissue surgical robot.
- Project lead of the patented surgeon console immobilization system
- Designed, tested and implemented robotic subsystems
- Managed the capital equipment packaging project as team lead
- Diagnosed and debugged system-level mechanical and software issues in clinical settings
2018
Santa Clara, CA
Mechanical Engineering Intern
Ethicon Inc. (formerly Auris)
- Designed and manufactured an immobilization actuator for a surgical system
- Assembled, tested and characterized robotic arm performance
2017
Goleta, CA
Mechanical Engineering Intern
Orbital ATK
- Prototyped assembly methods for satellite deployables
- Assembled and tested engineering development units
2015 – 2016
Kent, WA
Mechanical Engineering Intern
Breedt
- Designed, manufactured and tested large-scale industrial tooling
- Mechanical and electrical design of a robotic hydroponic foam cutter
EDUCATION
M.Sc. Mechatronics
MCI, Innsbruck, Austria
Oct 2023 – Jul 2025
B.Sc. Aerospace Engineering
Cal Poly San Luis Obispo, USA
Sept 2015 – Jun 2019
PUBLICATIONS & PATENTS
L. Nolan, M. Messner, S. Winkler, Y. Kim, “Implementation of an Advanced Control System for a Teleoperated Surgical Robot Using ROS 2,” IEEE ICARM 2026.
Surgeon console immobilization system, Ethicon Inc. Patents US20230390010A1 and WO2023238053A1.
LANGUAGES
English (native) · Norwegian (basic) · German (basic)
SKILLS
Robotics & controls
- ROS 2
- micro-ROS
- Gazebo
- RViz
- LQR / LQI
- System ID
- Simulink
- MATLAB
- Python
- C++
- OpenCV
- Linux
- Git
- GitHub Actions
Mechanical design
- SolidWorks
- Onshape
- Inventor
- Fusion 360
- GD&T
- DFMEA
- FEA
- Ansys
Manufacturing
- CNC
- Mastercam
- Fusion CAM
- BobCAM
- 3D printing
- Waterjet
- Laser cutting
SIDE PROJECTS
Side projects
Things I have built in my spare time, at university and in FIRST Robotics, BattleBots and PolySat.
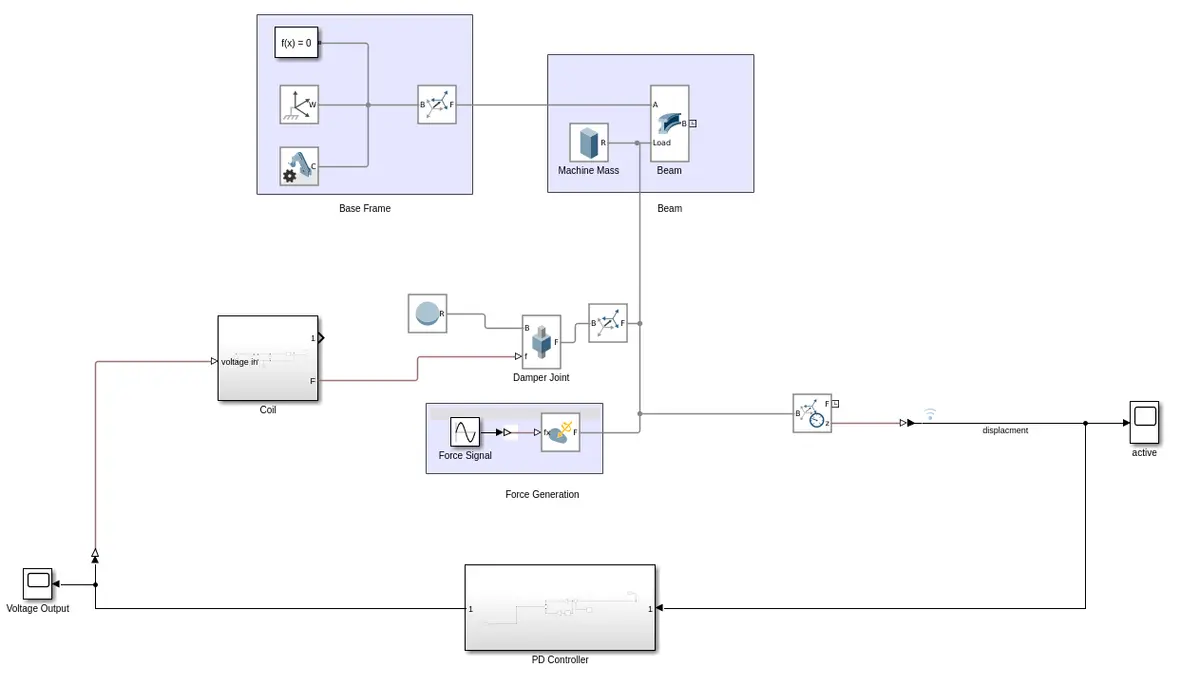
Beam Simulation and Control
March 2025
View projectBeam Simulation and Control
Dynamic simulation and passive / active damping of an I-beam in Simulink and Simscape Multibody.
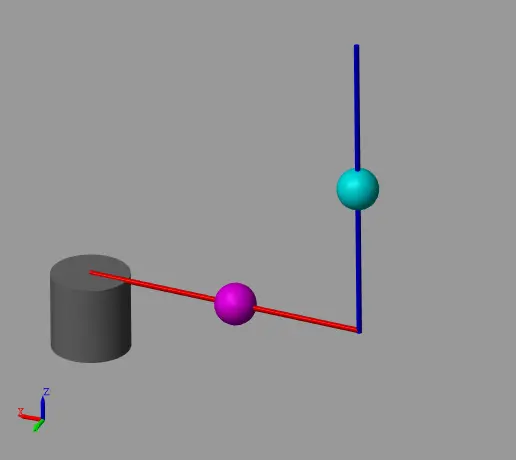
Futura Pendulum
March 2025
View projectFutura Pendulum
Modelling and LQR control of a Futura-style rotary pendulum in Simscape.
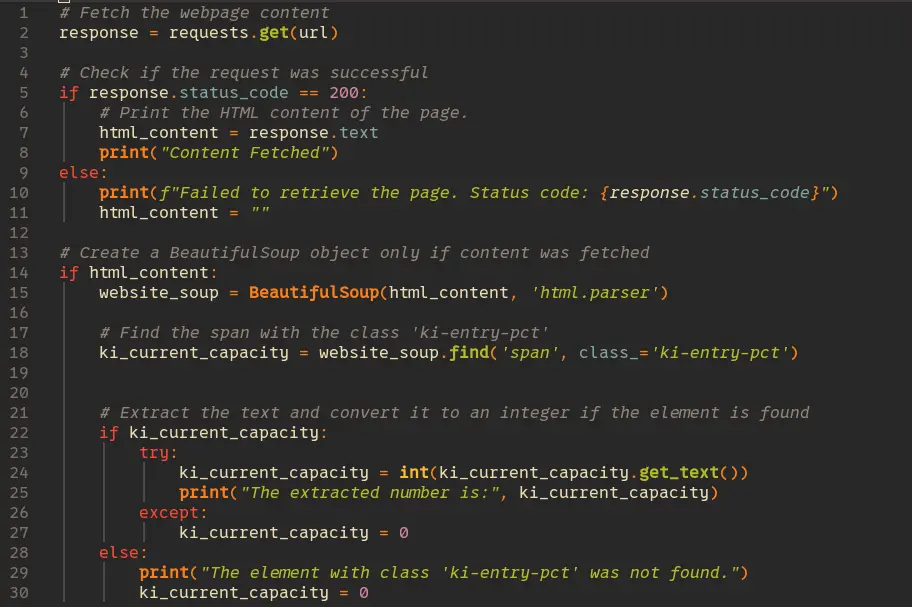
Python Webscraper
November 2024
View projectPython Webscraper
Collects, tracks and displays my climbing gym’s capacity, automated with GitHub Actions.
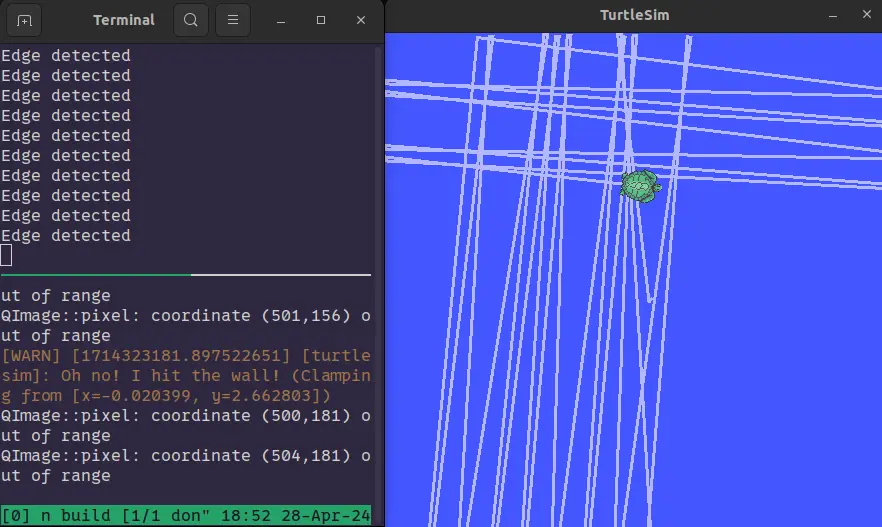
ROS 2 Turtlesim Edge Detection
April 2024
View projectROS 2 Turtlesim Edge Detection
Custom C++ ROS 2 node that drives a turtlebot and turns when it detects an edge.
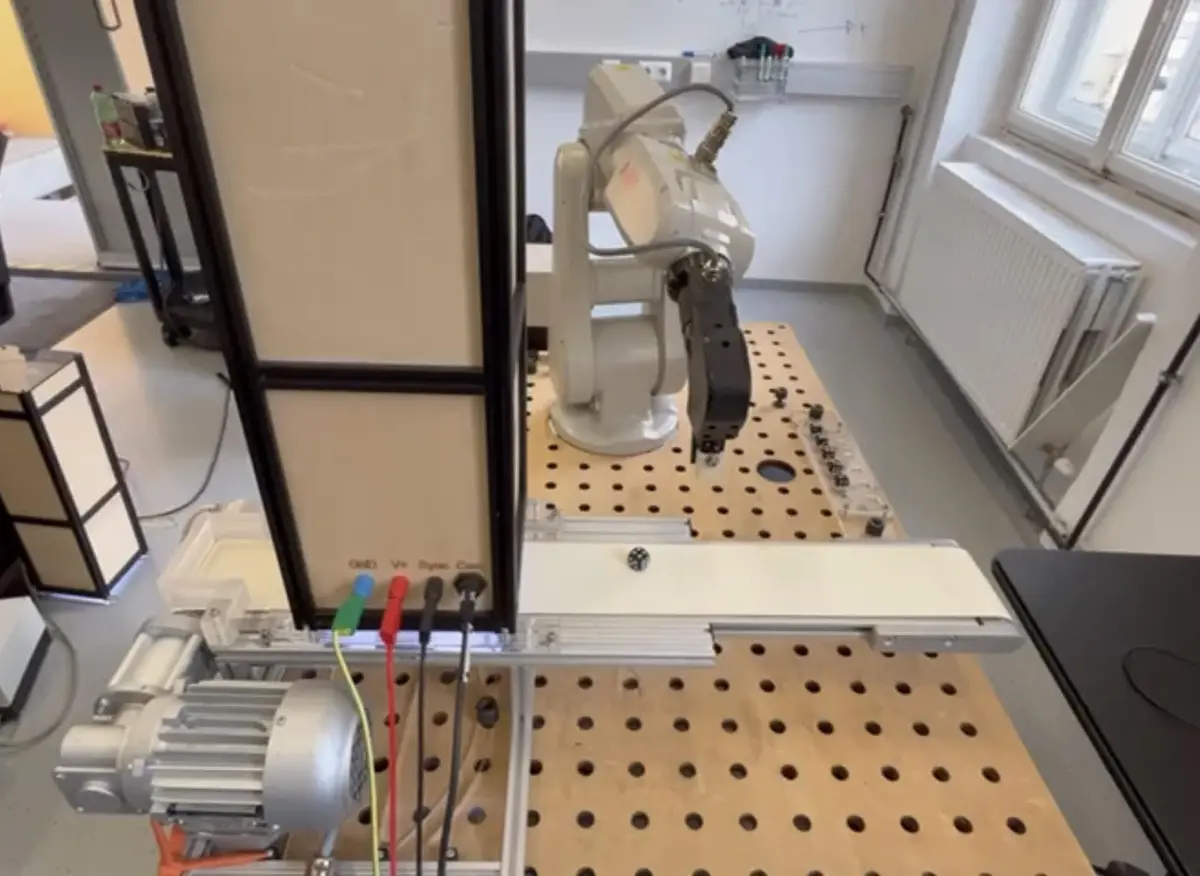
Dice Sorting Robot
April 2024
View projectDice Sorting Robot
ABB robot arm and Cognex vision that pick, sort and place dice, programmed in RAPID.
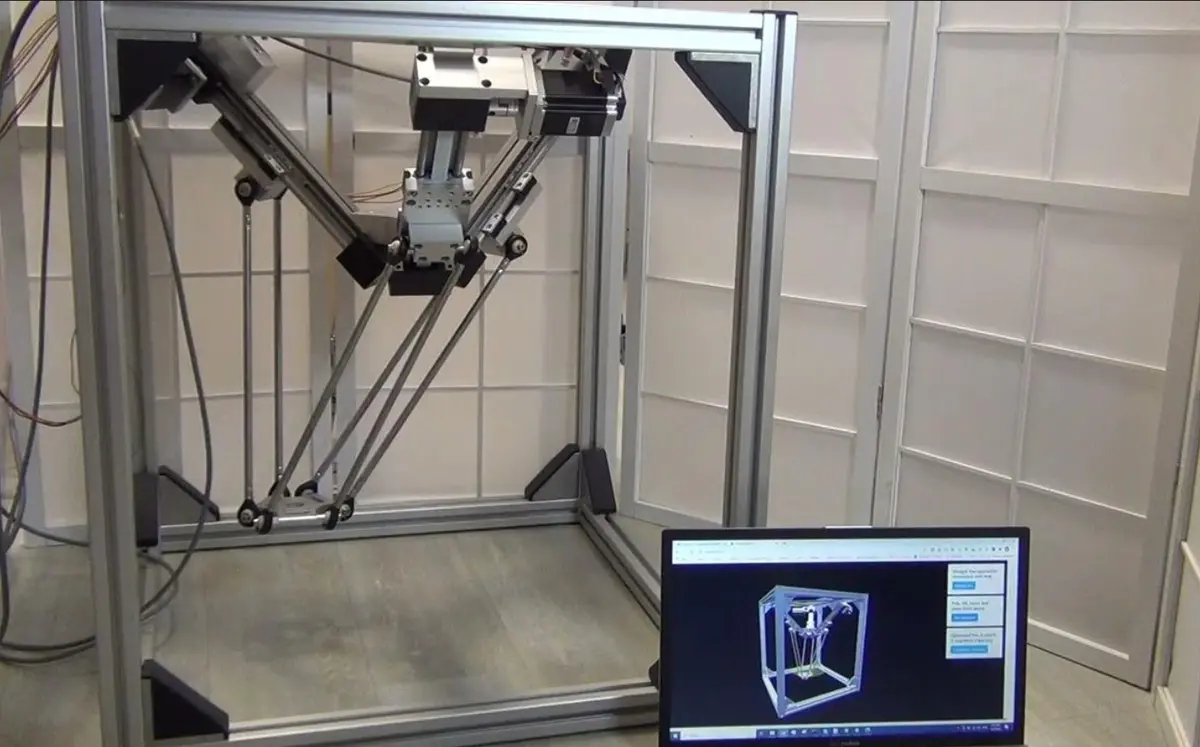
Delta Manipulator Simulation
April 2024
View projectDelta Manipulator Simulation
Trajectory planning and kinematics of an IGUS delta robot in MATLAB and Simscape.
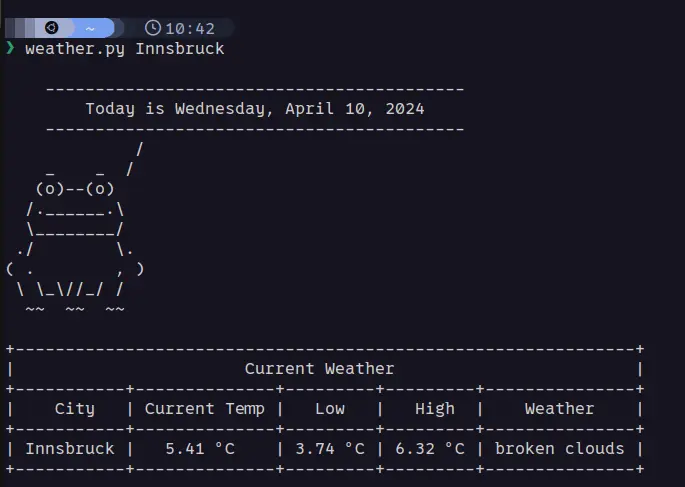
Weather Frog
January 2024
View projectWeather Frog
A helpful terminal frog that tells you the weather.
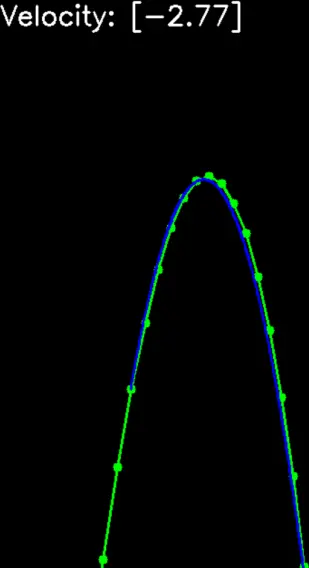
Python Trajectory Tracker
December 2023
View projectPython Trajectory Tracker
OpenCV script that tracks and predicts the trajectory of a thrown ball.
Havoc
2018
View projectHavoc
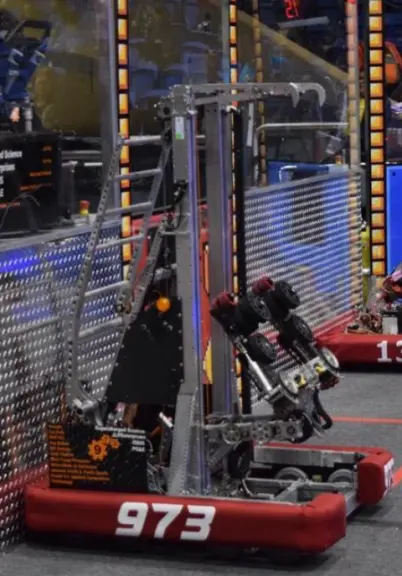
2018 FRC robot, Team 973. I coordinated design and manufacturing of the lift.
ISX
2018
View projectISX
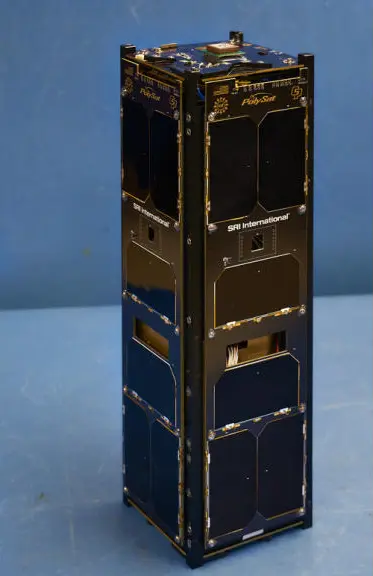
3U CubeSat measuring broadcast wave scintillation. Radiation analysis and code optimisation.
Bloodhound
2017
View projectBloodhound
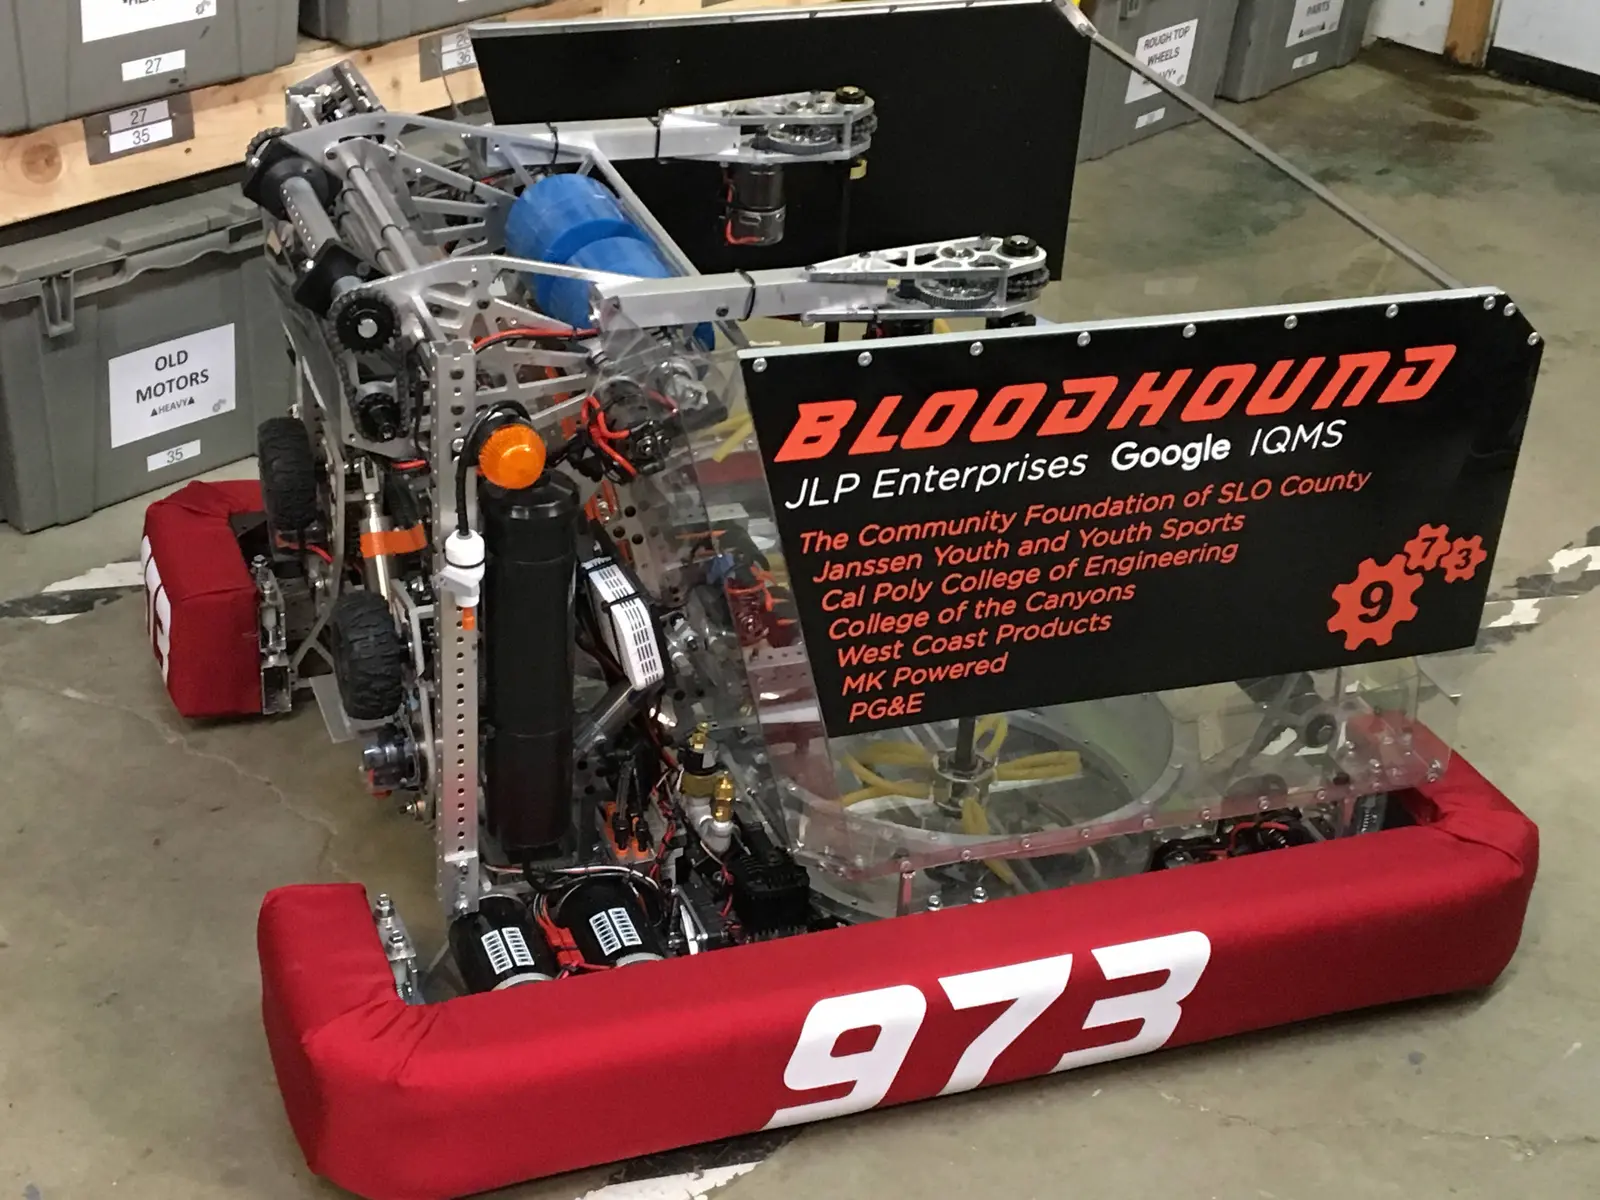
2017 FRC World Champion robot, Team 973, where I was a mentor.
Alexi
2016
View projectAlexi
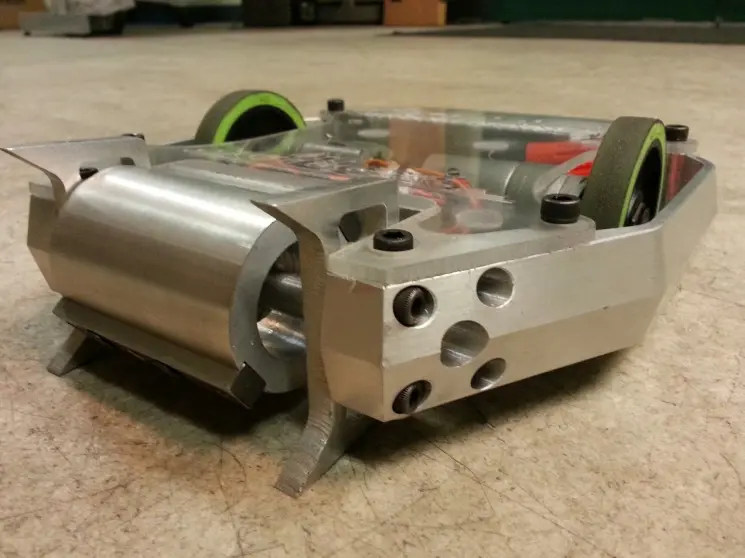
3 lb combat robot I designed, machined and tested myself.
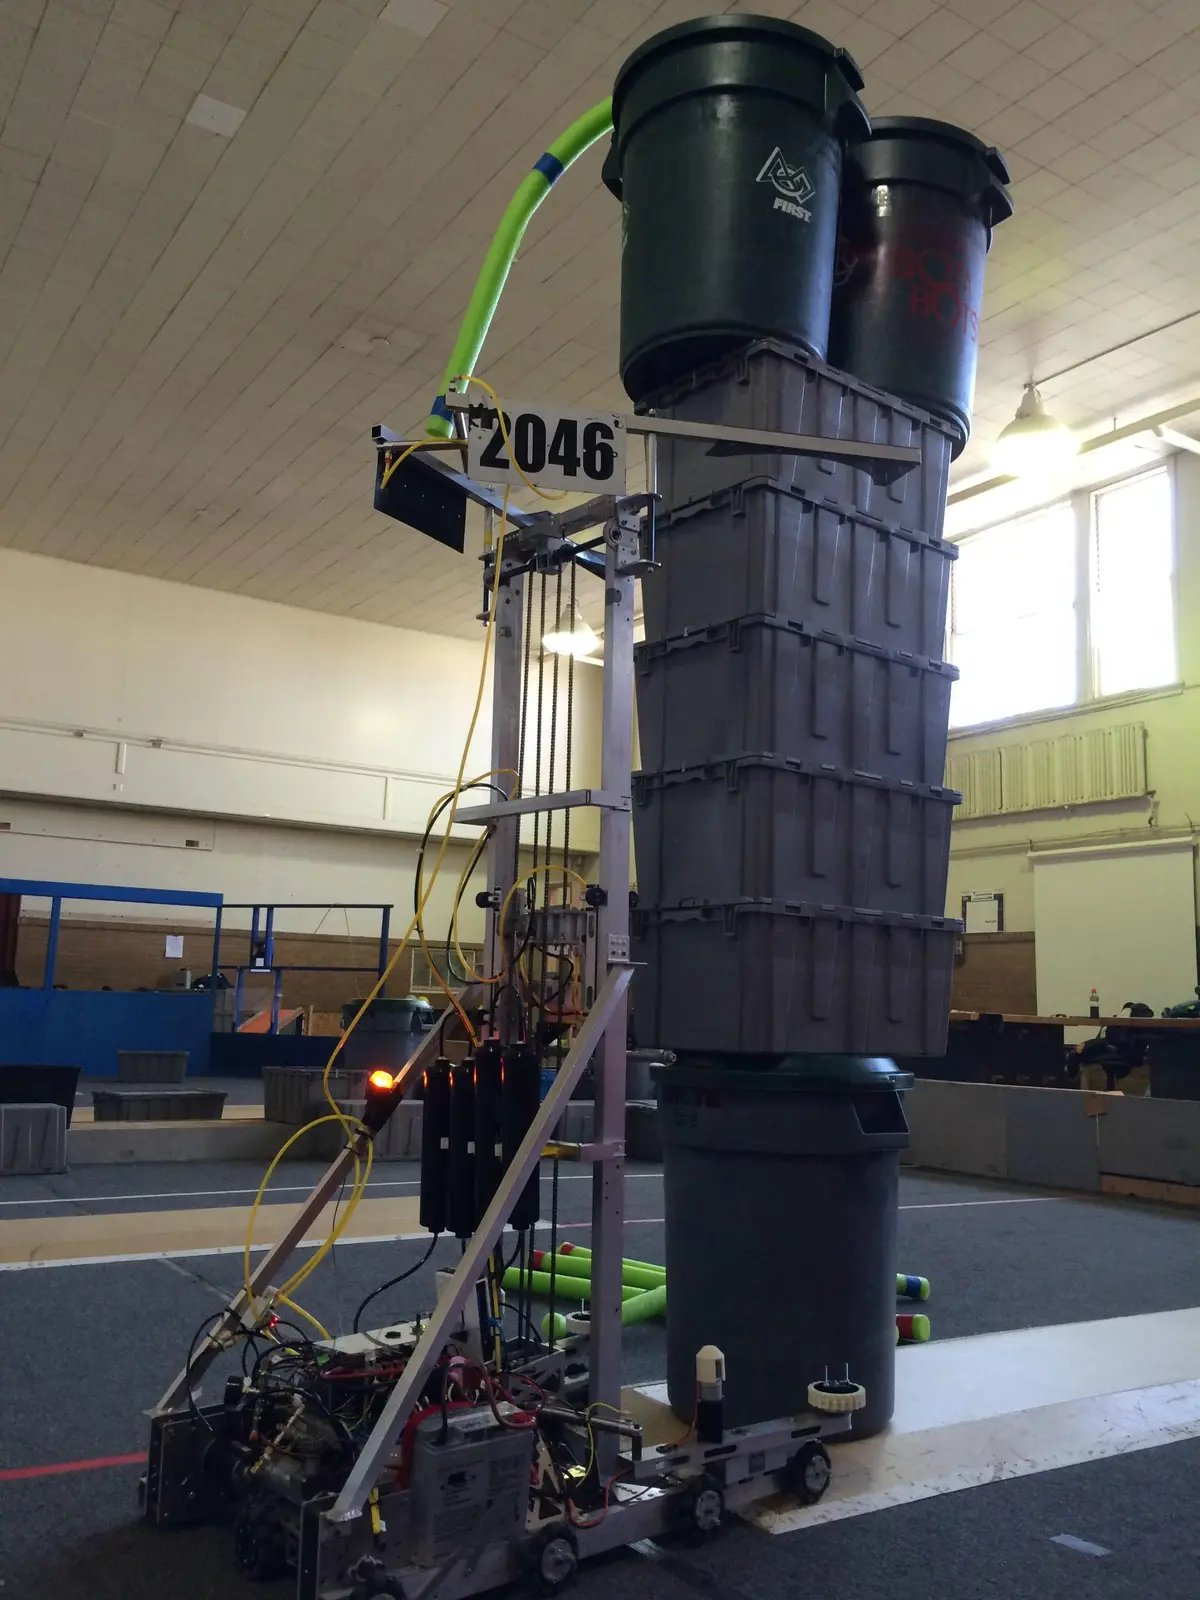
Maverick
2015
View projectMaverick
2015 FRC robot, Team 2046. World Championship Curie division finalist.
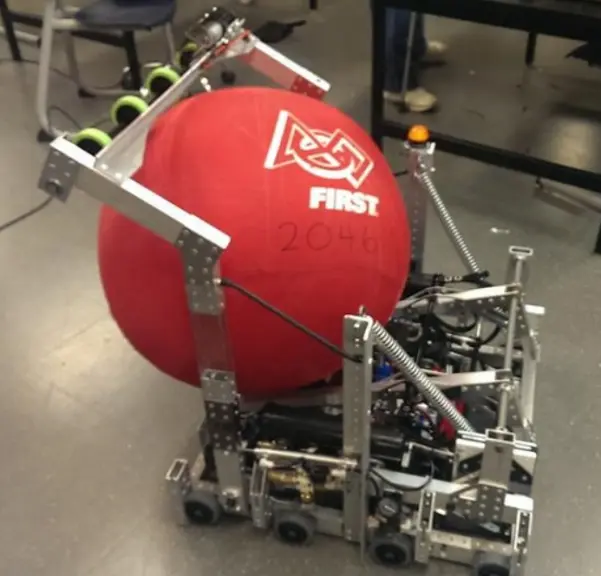
Bearium
2014
View projectBearium
2014 FRC robot, Team 2046. Auburn Regional winner.
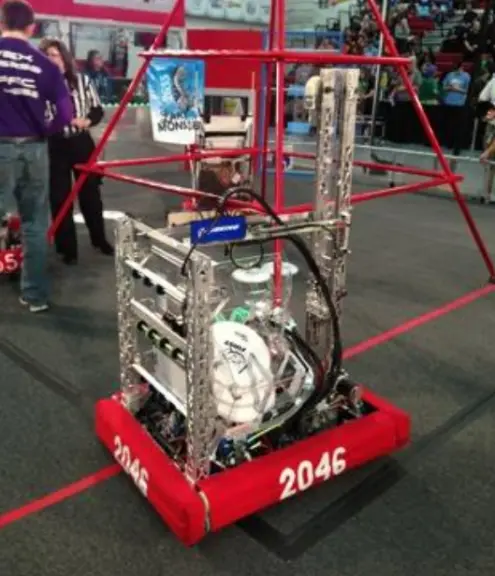
Bearadactyl
2013
View projectBearadactyl
2013 FRC robot, Team 2046. Portland Regional winner.
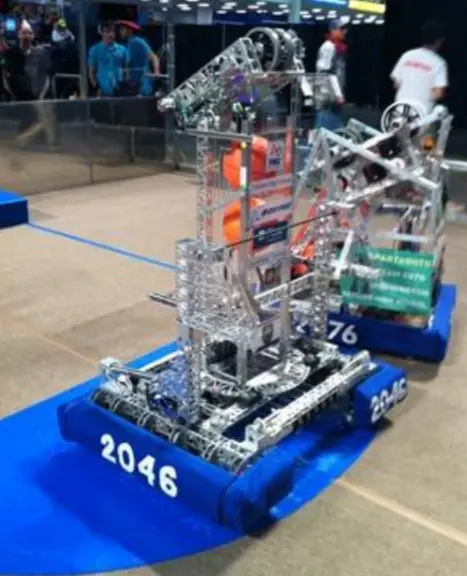
Bearmaggedon
2012
View projectBearmaggedon
2012 FRC robot, Team 2046. I manufactured the chassis.
Get in touch