Master's thesis · MCI Innsbruck
Desktop da Vinci
Overview
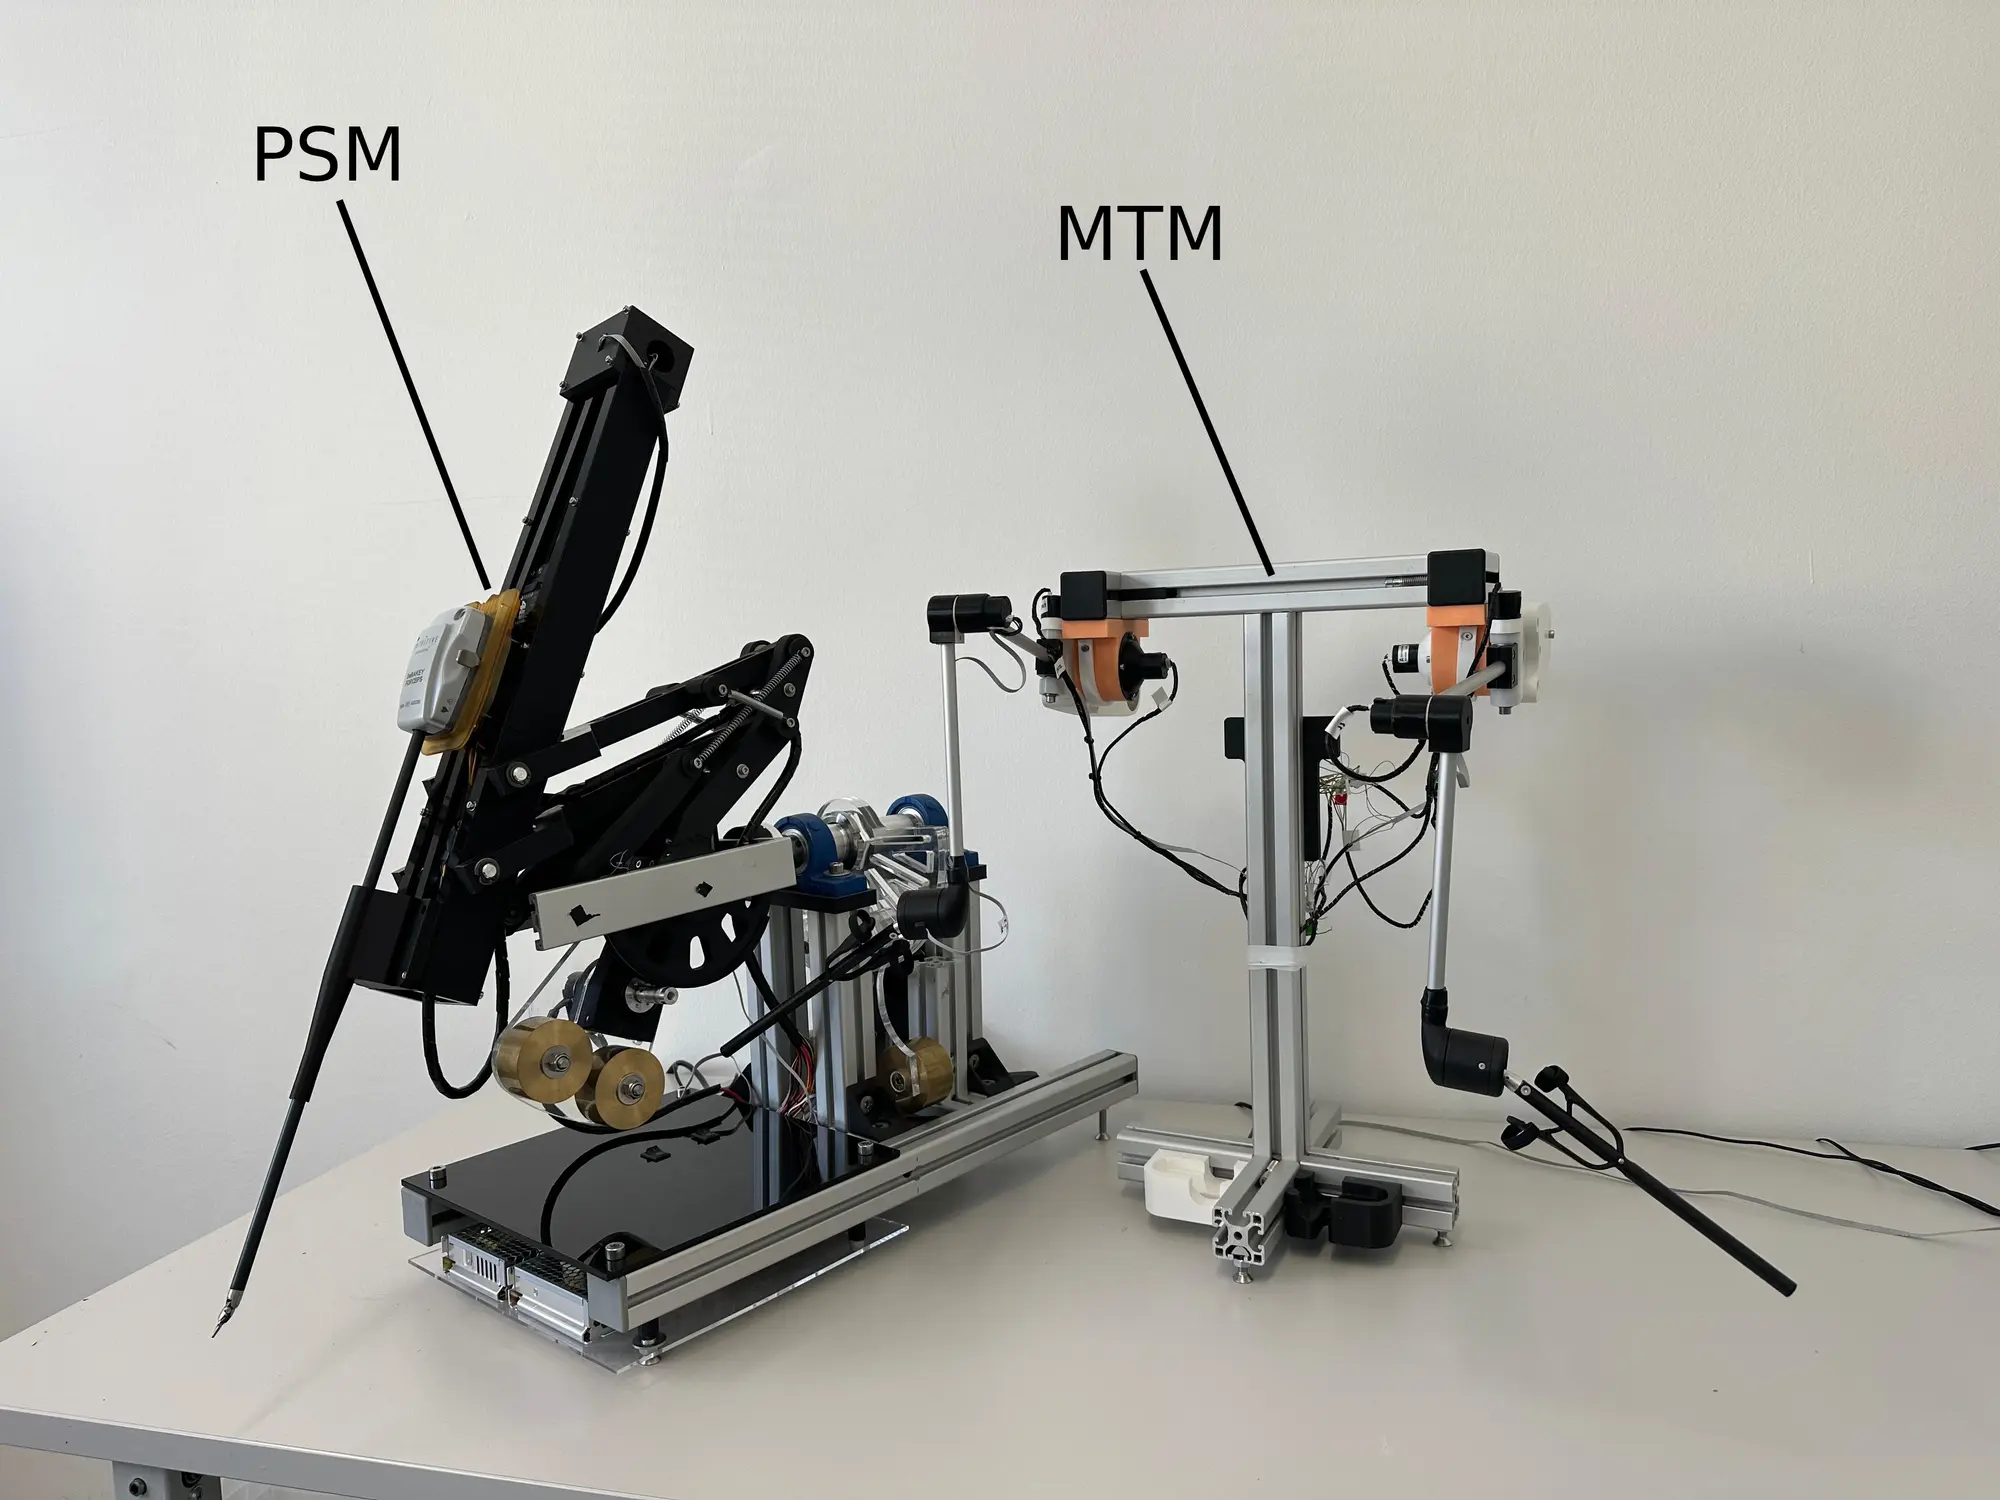
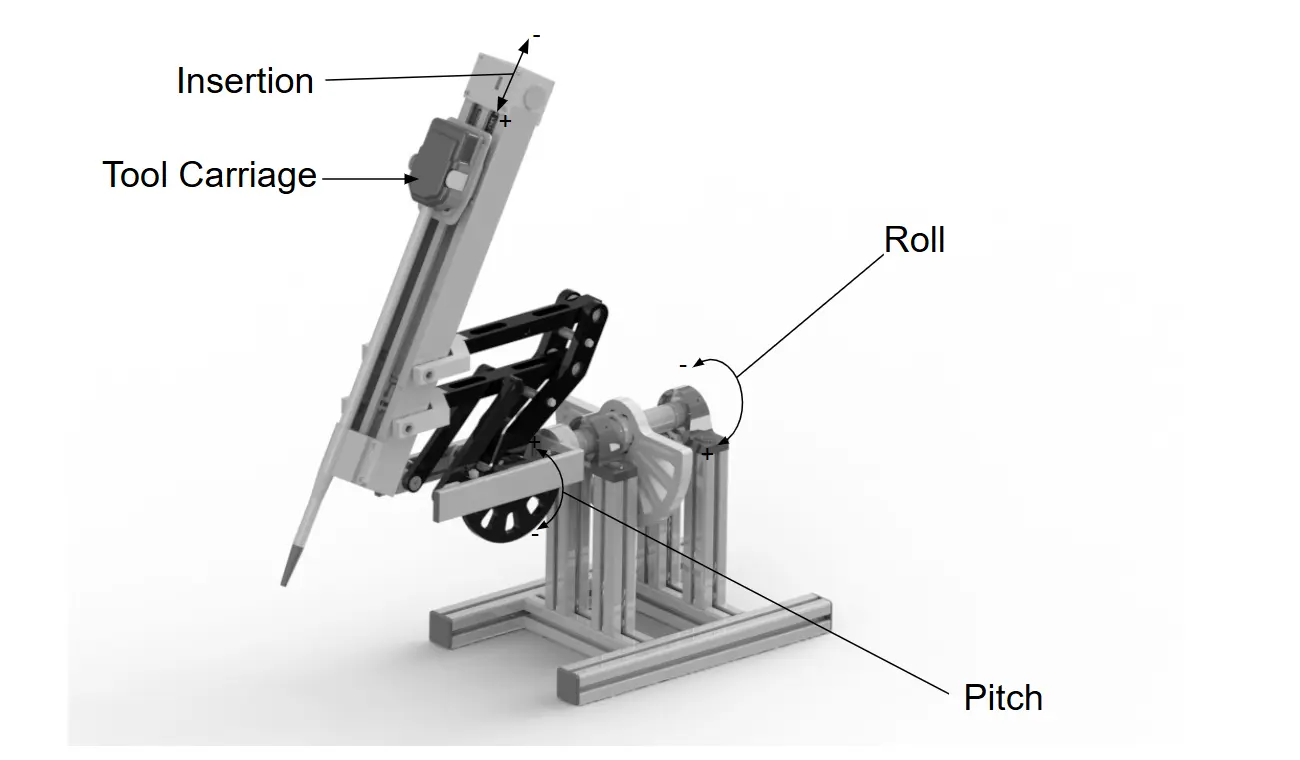
ROS 2-based Implementation of Advanced Control for a Teleoperated Surgical Robot. A desktop teleoperated surgical training system, with a master tool manipulator (MTM) and a patient side manipulator (PSM), built from affordable off-the-shelf hardware as an accessible platform for research and training. I ported the robot to ROS 2 / micro-ROS in C++ and built a URDF/SDF kinematic model from SolidWorks with TF forward kinematics in RViz.
L. Nolan, M. Messner, S. Winkler, and Y. Kim, “Implementation of an Advanced Control System for a Teleoperated Surgical Robot Using ROS 2,” IEEE International Conference on Advanced Robotics and Mechatronics (ICARM), 2026.
The challenge
Laparoscopic surgical robots are too expensive for most research and training. I identified the joint dynamics with step-response and closed-loop PRBS system identification, then designed gain-scheduled LQR and LQI + feedforward controllers. Mean tracking error dropped by 94% (pitch) and 74% (roll) compared with proportional control. The results are published with me as first author at IEEE ICARM 2026.
Get in touch