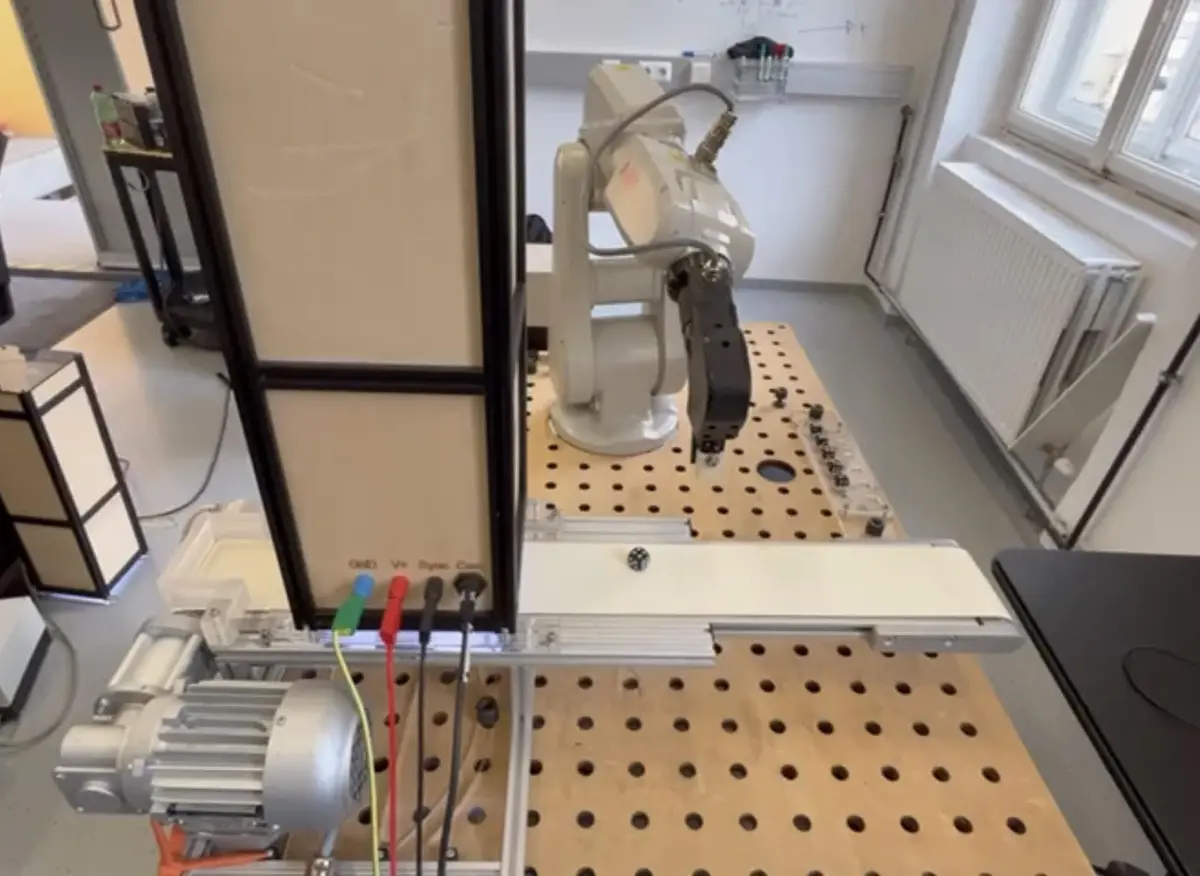
This project used an ABB robot arm and a Cognex camera to track, pick up and sort dice into a tray. The robot’s move instructions were all programmed in RAPID, with the vision processing handled by a custom program running on the Cognex camera. The robot would pick up a die from a tray, drop it onto the conveyor and then determine where to place it. It would repeat indefinitely or until stopped by the user.
← Side projects
Dice Sorting Robot
ABB robot arm and Cognex vision that pick, sort and place dice, programmed in RAPID.
Get in touch