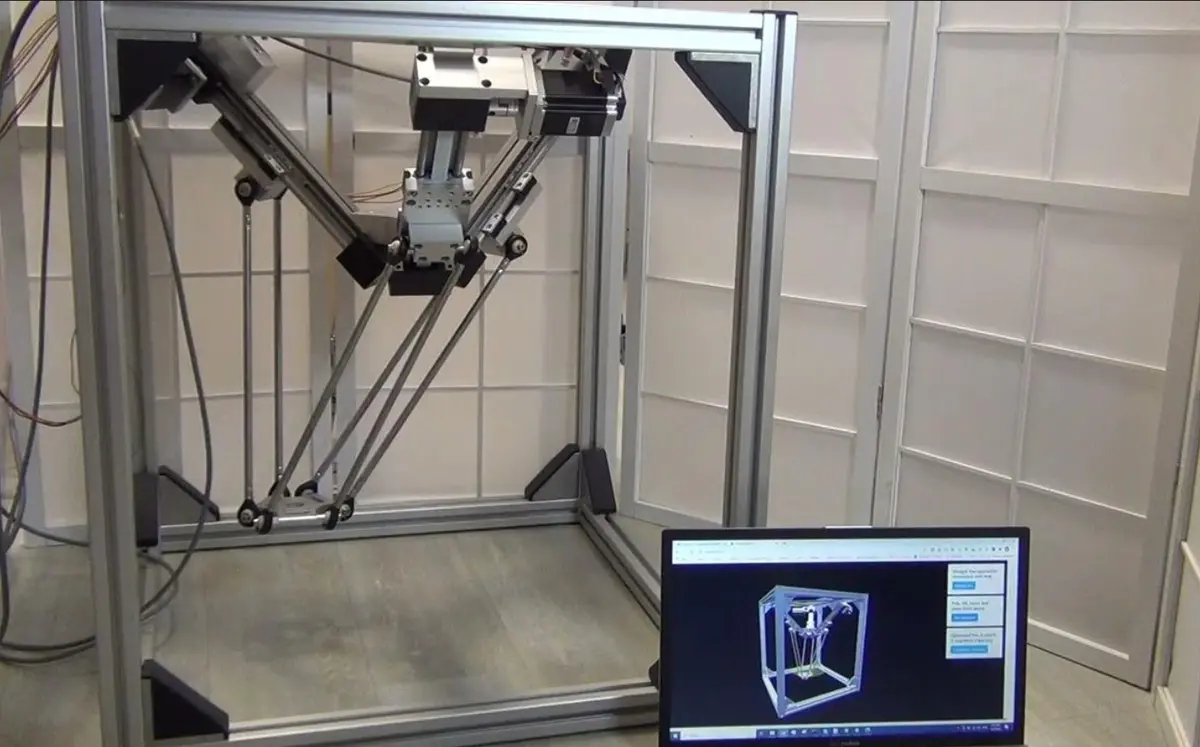
This project used MATLAB, Simulink and Simscape Multibody to model and simulate an IGUS Delta Manipulator. A desired trajectory path for the end effector was planned using trapezoidal velocity profiles. Inverse kinematics were then used to calculate joint positions based on the desired trajectory, and forward kinematics were used to calculate the new end effector position and update the Simscape model.
← Side projects
Delta Manipulator Simulation
Trajectory planning and kinematics of an IGUS delta robot in MATLAB and Simscape.
Get in touch